Contraction-Aware Reinforcement Learning for Nonlinear Control with Statistical Robustness
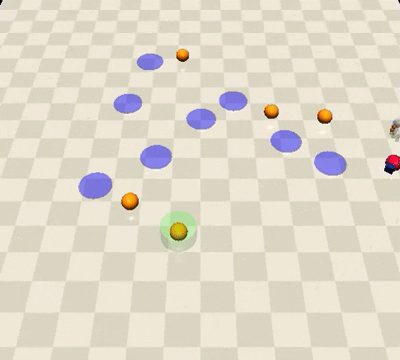
TL;DR — We propose contraction-aware reinforcement learning (CARL), which simultaneously learns control contraction metrics (CCMs) and optimizes a policy against rewards defined by those metrics, yielding stable and statistically robust path tracking for high-dimensional nonlinear systems.